Language-Conditioned Off-Road Planning
Robot-adaptive route planning that grounds mission preferences in semantic terrain and traversal consequences.
Natural-language mission preferences should influence a route only where the terrain and the active robot provide a feasible alternative. This project combines semantic region grounding, robot-specific traversal consequences, and corridor-bounded route selection for wheeled and legged robots.
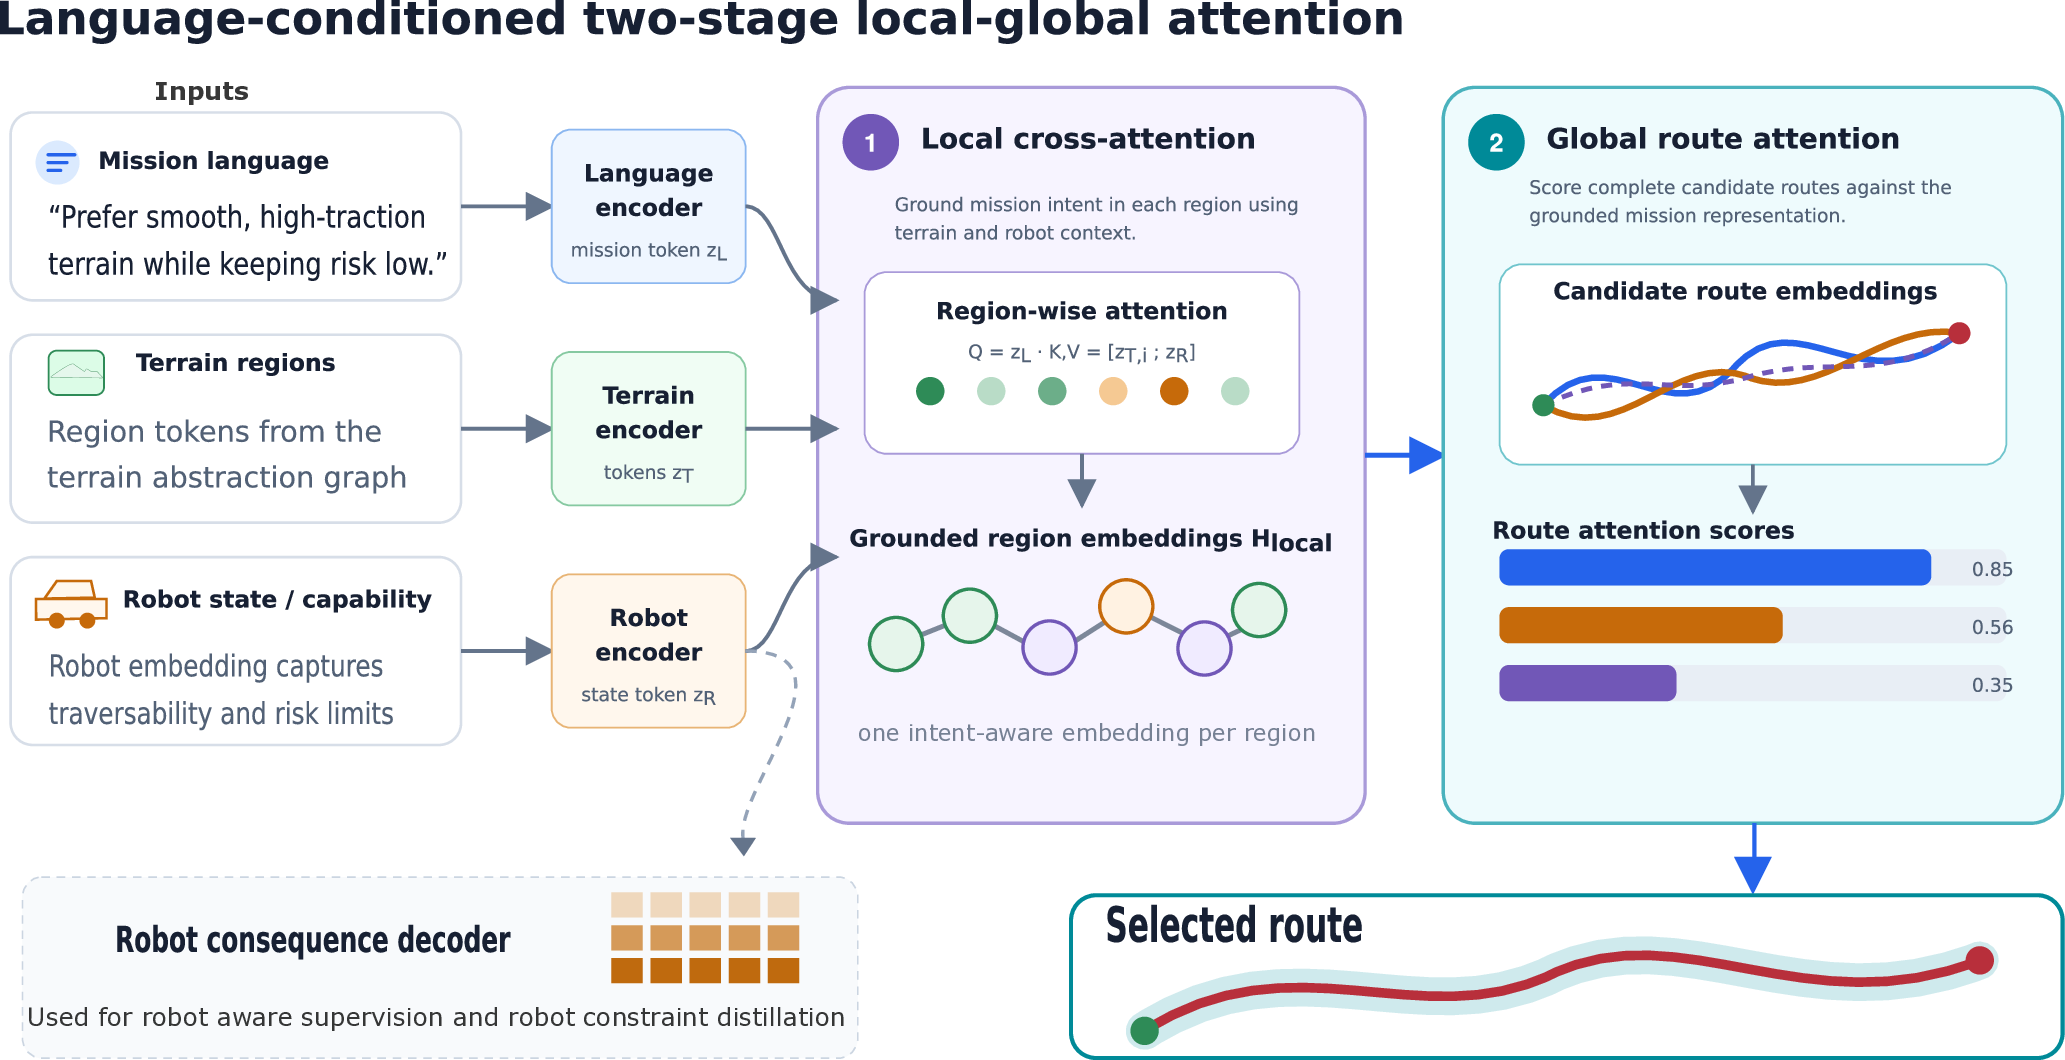
The architecture separates language values from path consequences: instructions can change without rebuilding the map, while changing the robot swaps the traversal model rather than the terrain representation. A live language model is not required in the per-query planning loop.
Current focus
- Ground typed mission objectives in semantic terrain regions.
- Generate robot-feasible candidates within a bounded corridor.
- Compare complete routes using language, terrain exposure, and robot consequences.
- Evaluate transfer across map scales and between Clearpath Jackal and Boston Dynamics Spot models.