<?xml version="1.0" encoding="utf-8"?><feed xmlns="http://www.w3.org/2005/Atom" xml:lang="en"><generator uri="https://jekyllrb.com/" version="4.4.1">Jekyll</generator><link href="https://pranayspeed.github.io/feed.xml" rel="self" type="application/atom+xml" /><link href="https://pranayspeed.github.io/" rel="alternate" type="text/html" hreflang="en" /><updated>2026-09-23T15:37:24+00:00</updated><id>https://pranayspeed.github.io/feed.xml</id><title type="html">blank</title><subtitle>Research portfolio of Pranay Meshram: language-conditioned planning, terrain abstraction, 3D perception, and field robotics.
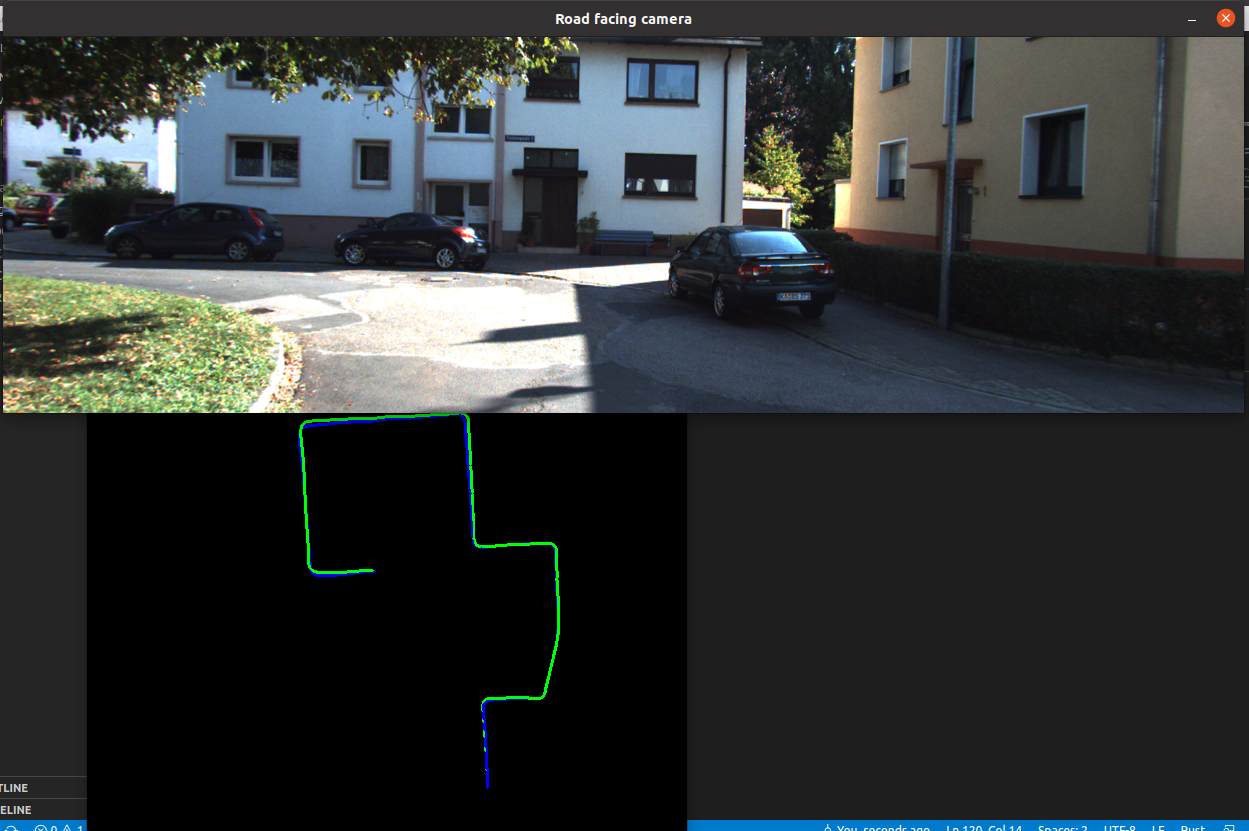
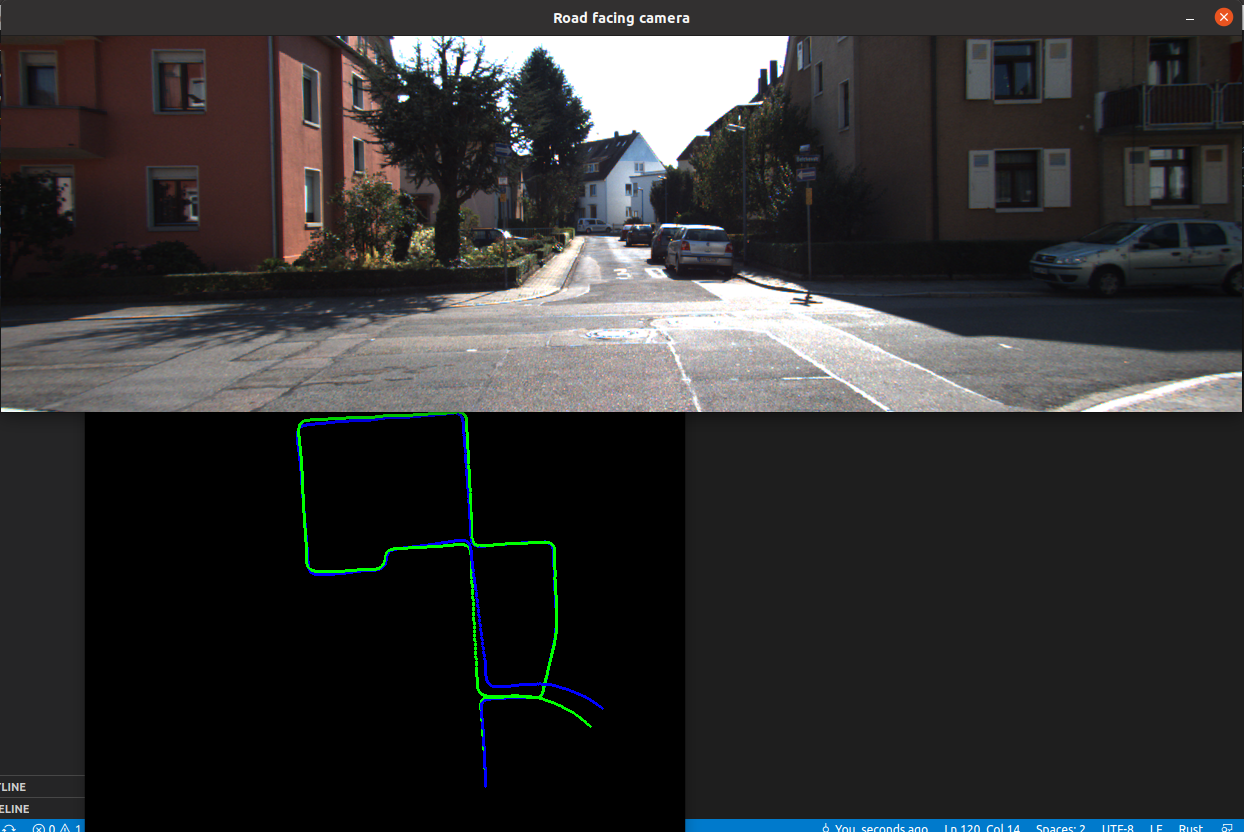
</subtitle><entry><title type="html">Monocular Visual Odometry in Rust (KITTI)</title><link href="https://pranayspeed.github.io/updates/2022/mono-vo/" rel="alternate" type="text/html" title="Monocular Visual Odometry in Rust (KITTI)" /><published>2022-07-08T04:00:00+00:00</published><updated>2022-07-08T04:00:00+00:00</updated><id>https://pranayspeed.github.io/updates/2022/mono-vo</id><content type="html" xml:base="https://pranayspeed.github.io/updates/2022/mono-vo/"><![CDATA[<p>Built a monocular visual odometry (VO) pipeline in Rust on the KITTI benchmark. Implemented feature tracking, pose estimation, and trajectory reconstruction, with plotting utilities to compare estimated trajectories against ground truth.</p>

<p>Benchmarked VO accuracy across sequences and experimented with tuning feature detection thresholds and RANSAC parameters to handle motion blur and texture-poor regions. Added demos and visualizations to highlight drift over long trajectories and loop-closure opportunities.</p>

<h2 id="git-repository"><a href="https://github.com/pranayspeed/mono-vo-rust">Git Repository</a></h2>
<p>layout: post
title: Monocular Visual Odometry (Rust)
—</p>

<ul>
  <li>Monocular visual odometry implementation based on <a href="https://avisingh599.github.io/vision/monocular-vo/">blog post</a></li>
  <li>The implementation is done is Rust.</li>
  <li>Used Kitti dataset for experiment.</li>
  <li><a href="https://github.com/pranayspeed/mono-vo-rust">Git Repository</a></li>
</ul>

<p><img src="/public/images/monovo_1.png" alt="Monovo1" />
<img src="/public/images/monovo_2.png" alt="Monovo2" /></p>]]></content><author><name></name></author><category term="blog" /><summary type="html"><![CDATA[Built a monocular visual odometry (VO) pipeline in Rust on the KITTI benchmark. Implemented feature tracking, pose estimation, and trajectory reconstruction, with plotting utilities to compare estimated trajectories against ground truth.]]></summary></entry><entry><title type="html">DAC SDC 2022 – FPGA-Friendly CNN (UBPercept)</title><link href="https://pranayspeed.github.io/updates/2022/dac-sdc/" rel="alternate" type="text/html" title="DAC SDC 2022 – FPGA-Friendly CNN (UBPercept)" /><published>2022-06-21T04:00:00+00:00</published><updated>2022-06-21T04:00:00+00:00</updated><id>https://pranayspeed.github.io/updates/2022/dac-sdc</id><content type="html" xml:base="https://pranayspeed.github.io/updates/2022/dac-sdc/"><![CDATA[<p><strong>DAC System Design Contest 2022</strong> – 4th place (UBPercept). Built an FPGA-friendly CNN pipeline on Ultra96V2 with quantization-aware training and deployment automation, targeting tight latency/memory budgets.</p>

<p>Led a 7-member team through data curation, profiling, and inference optimization; automated builds and on-board evaluation to iterate rapidly on accuracy–efficiency trade-offs. Documented lessons on model pruning and kernel fusion for edge devices.</p>

<p><a href="https://byuccl.github.io/dac_sdc_2022/results/">Results</a></p>]]></content><author><name></name></author><category term="blog" /><summary type="html"><![CDATA[DAC System Design Contest 2022 – 4th place (UBPercept). Built an FPGA-friendly CNN pipeline on Ultra96V2 with quantization-aware training and deployment automation, targeting tight latency/memory budgets.]]></summary></entry><entry><title type="html">DAC SDC 2022 - 4th Place (UBPercept)</title><link href="https://pranayspeed.github.io/updates/2022/DAC-SDC-2022/" rel="alternate" type="text/html" title="DAC SDC 2022 - 4th Place (UBPercept)" /><published>2022-06-21T00:00:00+00:00</published><updated>2022-06-21T00:00:00+00:00</updated><id>https://pranayspeed.github.io/updates/2022/DAC-SDC-2022</id><content type="html" xml:base="https://pranayspeed.github.io/updates/2022/DAC-SDC-2022/"><![CDATA[<ul>
  <li><strong>DAC System Design Contest 2022</strong> (June 2022) - 4th place [UBPercept] <a href="https://byuccl.github.io/dac_sdc_2022/results/">Results</a>
    <blockquote>
      <p>Contirbution</p>
      <ul>
        <li>Led the team of 7 and contributed towards initial investigation and implementation.</li>
        <li>Worked in a team to create plan for CNN training and deployment to FPGA (Ultra96V2)</li>
        <li>Major contribution in automating the deployment and result analysis for fast and efficient experiments.</li>
      </ul>
    </blockquote>
  </li>
</ul>]]></content><author><name></name></author><summary type="html"><![CDATA[DAC System Design Contest 2022 (June 2022) - 4th place [UBPercept] Results Contirbution Led the team of 7 and contributed towards initial investigation and implementation. Worked in a team to create plan for CNN training and deployment to FPGA (Ultra96V2) Major contribution in automating the deployment and result analysis for fast and efficient experiments.]]></summary></entry><entry><title type="html">Cleaner Bot – Coverage Planning Demo</title><link href="https://pranayspeed.github.io/updates/2020/Cleaner-bot/" rel="alternate" type="text/html" title="Cleaner Bot – Coverage Planning Demo" /><published>2020-12-20T04:00:00+00:00</published><updated>2020-12-20T04:00:00+00:00</updated><id>https://pranayspeed.github.io/updates/2020/Cleaner-bot</id><content type="html" xml:base="https://pranayspeed.github.io/updates/2020/Cleaner-bot/"><![CDATA[<p>Cleaner Bot: a simple coverage-planning demo exploring unknown 2D space. Built a fixed-size unknown-environment exploration algorithm, visualized its sweep over the map, and linked a short video demo.</p>

<p>Includes an interactive JS implementation to illustrate the circular BFS-style sweep and coverage behavior.</p>

<div style="margin: 20px 0; text-align: center;">
  <iframe src="/project/botcleanerjs/index.html" width="320" height="320" style="border:1px solid #ccc;"></iframe>
</div>]]></content><author><name></name></author><category term="blog" /><summary type="html"><![CDATA[Cleaner Bot: a simple coverage-planning demo exploring unknown 2D space. Built a fixed-size unknown-environment exploration algorithm, visualized its sweep over the map, and linked a short video demo.]]></summary></entry><entry><title type="html">EBNF Grammar Parser in Python</title><link href="https://pranayspeed.github.io/updates/2019/ebnf-parser/" rel="alternate" type="text/html" title="EBNF Grammar Parser in Python" /><published>2019-03-06T04:00:00+00:00</published><updated>2019-03-06T04:00:00+00:00</updated><id>https://pranayspeed.github.io/updates/2019/ebnf-parser</id><content type="html" xml:base="https://pranayspeed.github.io/updates/2019/ebnf-parser/"><![CDATA[<p>Extended Backus–Naur Form grammar parser built from scratch in Python. Supports defining custom grammars, validating syntax, and running example parse workflows for compiler-construction practice and teaching.</p>

<p>Includes utilities for grammar inspection and error highlighting to help debug language specs and parser behavior on sample inputs.</p>

<p><a href="https://github.com/pranayspeed/GrammarParser">Git Repository</a></p>]]></content><author><name></name></author><category term="blog" /><summary type="html"><![CDATA[Extended Backus–Naur Form grammar parser built from scratch in Python. Supports defining custom grammars, validating syntax, and running example parse workflows for compiler-construction practice and teaching.]]></summary></entry><entry><title type="html">BNF and EBNF Grammer Parser</title><link href="https://pranayspeed.github.io/updates/2019/EBNF-Grammer-Parser/" rel="alternate" type="text/html" title="BNF and EBNF Grammer Parser" /><published>2019-03-06T00:00:00+00:00</published><updated>2019-03-06T00:00:00+00:00</updated><id>https://pranayspeed.github.io/updates/2019/EBNF-Grammer-Parser</id><content type="html" xml:base="https://pranayspeed.github.io/updates/2019/EBNF-Grammer-Parser/"><![CDATA[<ul>
  <li>Implemented  Extended Backus-Naur Form grammer parser from scratch.</li>
  <li>Following is a sample grammer that can be parsed using this implementation:
    <blockquote>
      <p>S := ‘Hello’ | ‘Hi’ P | P | ‘bye’ <br />
P := ‘World’ | ‘Everyone’ | ‘[A-Za-z0-9]+      ‘ | ‘a’</p>
    </blockquote>
  </li>
  <li>Developed in Python.</li>
  <li><a href="https://github.com/pranayspeed/GrammarParser">Git Repository</a></li>
</ul>]]></content><author><name></name></author><summary type="html"><![CDATA[Implemented Extended Backus-Naur Form grammer parser from scratch. Following is a sample grammer that can be parsed using this implementation: S := ‘Hello’ | ‘Hi’ P | P | ‘bye’ P := ‘World’ | ‘Everyone’ | ‘[A-Za-z0-9]+ ‘ | ‘a’]]></summary></entry><entry><title type="html">RL Self-Driving Agent (PyTorch)</title><link href="https://pranayspeed.github.io/updates/2018/self-driving-car/" rel="alternate" type="text/html" title="RL Self-Driving Agent (PyTorch)" /><published>2018-03-07T04:00:00+00:00</published><updated>2018-03-07T04:00:00+00:00</updated><id>https://pranayspeed.github.io/updates/2018/self-driving-car</id><content type="html" xml:base="https://pranayspeed.github.io/updates/2018/self-driving-car/"><![CDATA[<p>Reinforcement Learning driving agent that learns end-to-end navigation from start to goal on 2D road maps. Implemented in PyTorch with a Kivy UI for interactive visualization, reward diagnostics, and episode playback.</p>

<p>Explored reward shaping and curriculum tweaks to improve lane following, collision avoidance, and convergence speed. Logged metrics and rendered trajectories to compare training variants and diagnose failure cases in intersections and sharp turns.</p>

<p><a href="https://github.com/pranayspeed/SelfDrivingCar">Git Repository</a></p>]]></content><author><name></name></author><category term="blog" /><summary type="html"><![CDATA[Reinforcement Learning driving agent that learns end-to-end navigation from start to goal on 2D road maps. Implemented in PyTorch with a Kivy UI for interactive visualization, reward diagnostics, and episode playback.]]></summary></entry><entry><title type="html">Self Dirving Car - using Reinforcement Learning</title><link href="https://pranayspeed.github.io/updates/2018/self-driving-car-reinforcement-learning/" rel="alternate" type="text/html" title="Self Dirving Car - using Reinforcement Learning" /><published>2018-03-07T00:00:00+00:00</published><updated>2018-03-07T00:00:00+00:00</updated><id>https://pranayspeed.github.io/updates/2018/self-driving-car-reinforcement-learning</id><content type="html" xml:base="https://pranayspeed.github.io/updates/2018/self-driving-car-reinforcement-learning/"><![CDATA[<ul>
  <li>Implementation an Agent to learn to get from start to goal position, given 2D map with road.</li>
  <li>The Agent is support to follow the Road towards the goal position, and getting the highest reward.</li>
  <li>Developed in Python, using Pytorch and Kivy for UI.</li>
  <li><a href="https://github.com/pranayspeed/SelfDrivingCar">Git Repository</a></li>
</ul>]]></content><author><name></name></author><summary type="html"><![CDATA[Implementation an Agent to learn to get from start to goal position, given 2D map with road. The Agent is support to follow the Road towards the goal position, and getting the highest reward. Developed in Python, using Pytorch and Kivy for UI. Git Repository]]></summary></entry><entry><title type="html">Fusion 360 - 3MF exporter plugin</title><link href="https://pranayspeed.github.io/updates/2016/Fusion360-3MF-Exporter/" rel="alternate" type="text/html" title="Fusion 360 - 3MF exporter plugin" /><published>2016-09-02T00:00:00+00:00</published><updated>2016-09-02T00:00:00+00:00</updated><id>https://pranayspeed.github.io/updates/2016/Fusion360-3MF-Exporter</id><content type="html" xml:base="https://pranayspeed.github.io/updates/2016/Fusion360-3MF-Exporter/"><![CDATA[<ul>
  <li>Implemented Fusion 360 Collada exporter for generating 3MF model file from CAD Model designed in Fusion 360.
    <blockquote>
      <ul>
        <li>This plugin is helpful if you want to do 3D print the CAD design</li>
        <li>3MF support color in addition to triangulation</li>
        <li><a href="https://github.com/pranayspeed/Fusion360_Plugins">Git Repository</a></li>
      </ul>
    </blockquote>
  </li>
</ul>]]></content><author><name></name></author><summary type="html"><![CDATA[Implemented Fusion 360 Collada exporter for generating 3MF model file from CAD Model designed in Fusion 360. This plugin is helpful if you want to do 3D print the CAD design 3MF support color in addition to triangulation Git Repository]]></summary></entry><entry><title type="html">Fusion 360 - Collada exporter plugin</title><link href="https://pranayspeed.github.io/updates/2016/Fusion360-Collada-Exporter/" rel="alternate" type="text/html" title="Fusion 360 - Collada exporter plugin" /><published>2016-09-01T00:00:00+00:00</published><updated>2016-09-01T00:00:00+00:00</updated><id>https://pranayspeed.github.io/updates/2016/Fusion360-Collada-Exporter</id><content type="html" xml:base="https://pranayspeed.github.io/updates/2016/Fusion360-Collada-Exporter/"><![CDATA[<ul>
  <li>Implemented Fusion 360 Collada exporter for generating Collada model file from CAD Model designed in Fusion 360.
    <blockquote>
      <ul>
        <li>This plugin is helpful if you are a blender user and work with animation.</li>
        <li>Blender compatible model exported.</li>
        <li><a href="https://github.com/pranayspeed/Fusion360_Plugins">Git Repository</a></li>
      </ul>
    </blockquote>
  </li>
</ul>]]></content><author><name></name></author><summary type="html"><![CDATA[Implemented Fusion 360 Collada exporter for generating Collada model file from CAD Model designed in Fusion 360. This plugin is helpful if you are a blender user and work with animation. Blender compatible model exported. Git Repository]]></summary></entry></feed>